Challenge
Inspection and data-acquisition missions require the integration of a naval platform, propulsion, energy, communications, control and payload.
Autonomous systems
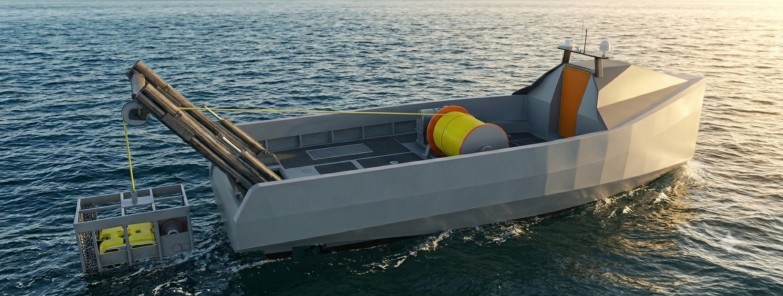
Integrated development of a surface platform designed to carry and support the deployment of small remotely operated vehicles.
Inspection and data-acquisition missions require the integration of a naval platform, propulsion, energy, communications, control and payload.
Develop an autonomous surface vessel with an architecture prepared to support mini-ROV operations.
The work combines hull, propulsion and steering design, electrical and electronic systems, telemetry, communications, automation and mission integration.
Advance a complete and verifiable architecture, reducing integration risks before future operational demonstrations.
R&D project developed in technical collaboration with LOC/COPPE/UFRJ and supported by EMBRAPII within its specific structure.